

Product details
Product Overview
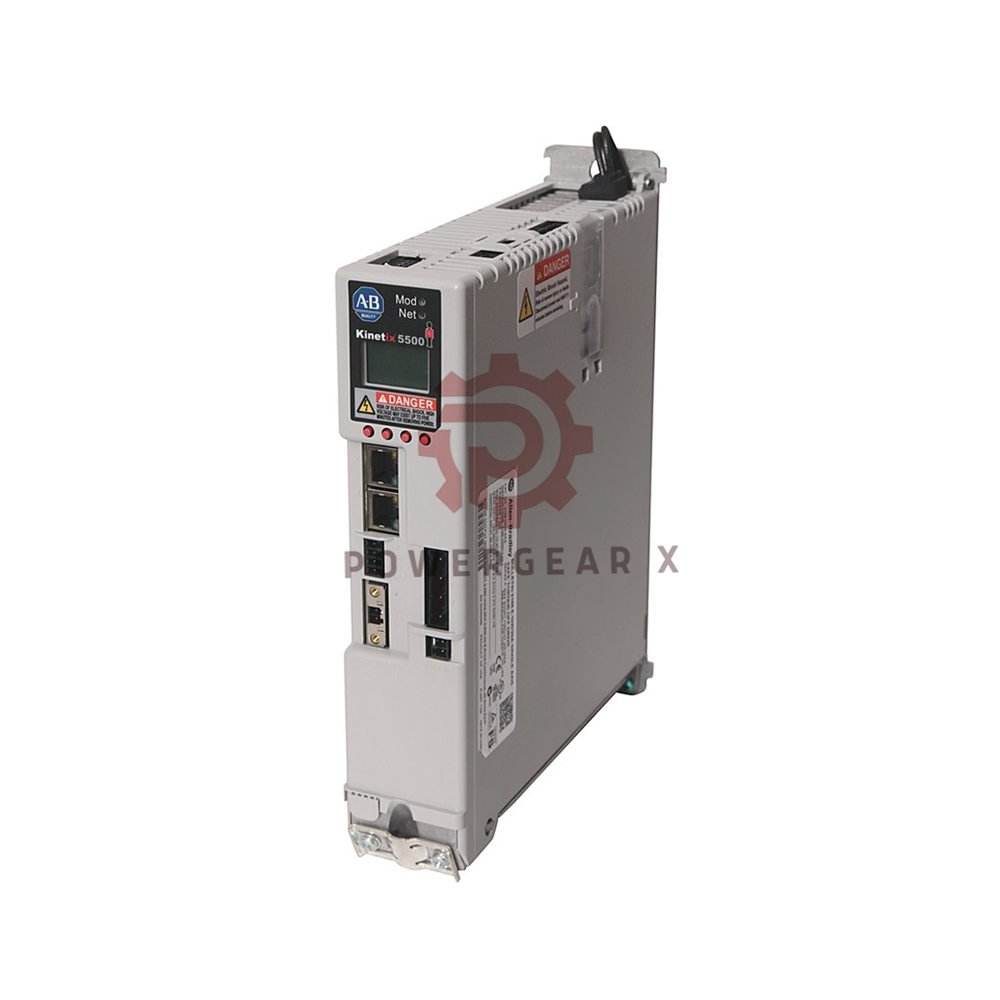
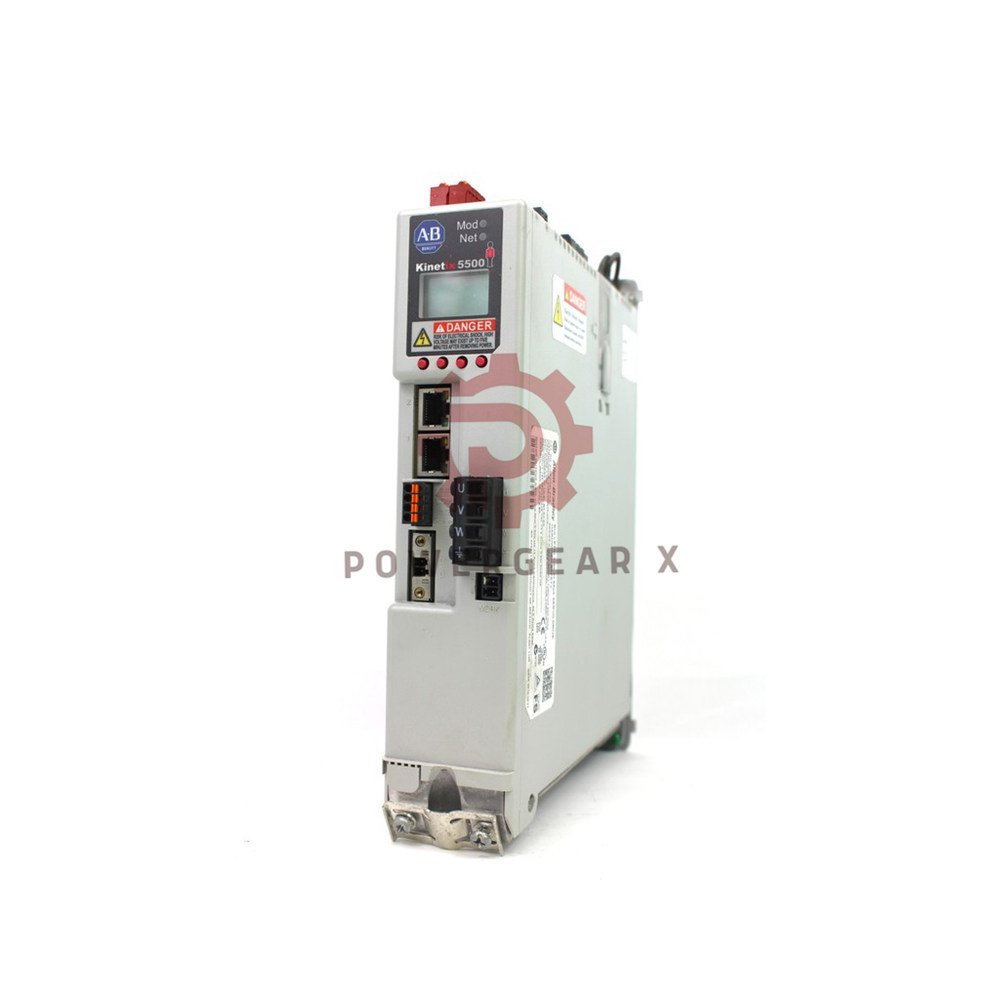
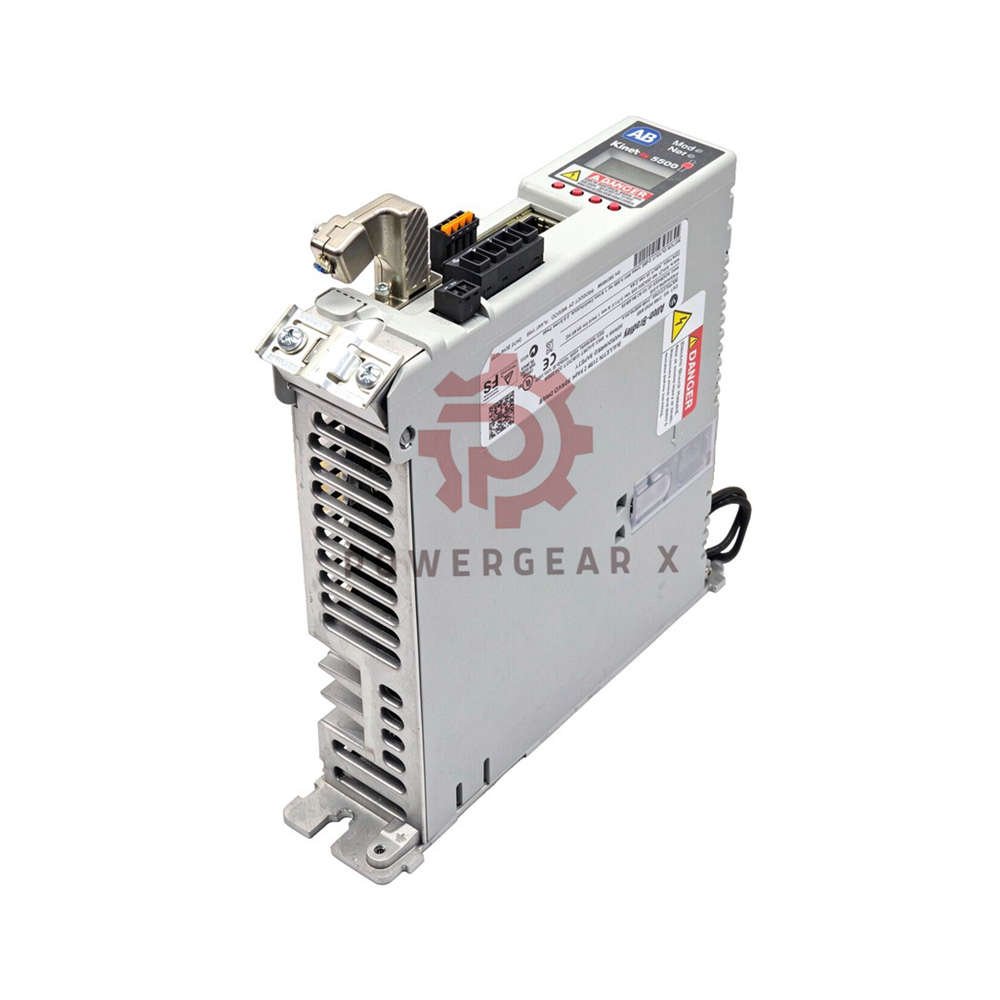
This is the 2198-C4007-ERS. It is a Kinetix 5300 servo drive. Allen-Bradley builds it, and Rockwell Automation supports it. The drive is a single-axis unit. It runs on 380–480V AC three-phase power. At 400V, it gives 1.55 kW of continuous output. Output current is 2.9 A rms. The frame is 1. It ships as IP20 and mounts inside a grounded cabinet. Two EtherNet/IP ports are built in. So is hardwired Safe Torque Off.
Catalog Code Tree
- 2198-C4007-ERS
- 2198-C → Kinetix 5300 servo drive family
- Integrated motion on EtherNet/IP
- 4007 → power and frame code
- 400V class
- 1.55 kW at 400V three-phase
- Frame 1
- ERS → EtherNet/IP servo drive
- Hardwired Safe Torque Off
- Dual-port network
- 2198-C → Kinetix 5300 servo drive family
Core Technical Data
- Brand: Allen-Bradley (Rockwell Automation)
- Model: 2198-C4007-ERS
- Series: Kinetix 5300
- Type: single-axis EtherNet/IP servo drive
- Input: 342–528V rms, three-phase (380–480V nominal)
- Input frequency: 47–63 Hz
- Control power: 21.6–26.4V DC (24V nominal)
- Continuous output power: 1.55 kW at 400V
- Continuous current: 2.9 A rms (4.1 A 0-pk)
- Peak current: 9.3 A rms for up to 1.0 s (13.2 A 0-pk)
- Main AC input current: 2.25 A rms
- Peak AC input current: 6.29 A rms
- Output frequency: 0–590 Hz max
- Efficiency: 97%
- Line loss ride-through: 20 ms
- Internal shunt: 100 Ω, 30 W; on 775V, off 765V
- External shunt options: 2097-R6 (75 Ω / 150 W), 2097-R7 (150 Ω / 80 W)
- Bus limits: overvoltage 810V; undervoltage 275V
- DC bus capacitance: 165 µF
- Short-circuit rating: 200,000 A rms symmetrical
- Overload: 110% of motor rating, solid-state fold-back
- Digital inputs: 4 configurable 24V DC fast inputs
- Motor brake output: 2.25 A at +24V, max 15 cycles/min
- Auxiliary feedback: AM, BM, IM differential plus 5V supply
- Motor feedback: 15-pin MFB connector
- Safe Torque Off: dual-channel hardwired, PL d / Cat 3 / SIL CL2
- Network: 2 × EtherNet/IP RJ45; linear, star, DLR
- Ethernet switch: 3-port cut-through, IEEE-1588 time correction
- Update period: 1.0 ms minimum
- Cable: CAT5e shielded up to 100 m
- Status display: 4-character display with navigation keys
- Power loss: 58 W at 100% rated output
- Size (H×W×D): 175.0 × 50.0 × 204.0 mm
- Weight: 1.34 kg (Frame 1)
- Heat range: 0…50 °C operating
- Storage: -35…+70 °C
- Humidity: 5–85% non-condensing (operating)
- Pollution degree: 2 (IEC 61800-5-1)
- Altitude: 1000 m
- Vibration: 0.35 mm (5–55 Hz); 2.0 g (55–500 Hz)
- Shock: 15 g, 11 ms half-sine
- Motor cable: up to 30 m; high-resolution feedback 50 m at ≤400V
Where It Fits Best
- Packaging machines with fast index moves.
- Pick-and-place robots and gantries.
- Converting lines that need tight tension.
- Filling and labeling stations.
- Machine tools with simple feed axes.
- Logix-based cells using CIP Motion.
- Safety zones that need STO up to PL d.
Installation and Setup
- Mount inside a grounded cabinet at pollution degree 2.
- Add the 2198-DB08-F line filter for CE compliance.
- Wire the dual-channel STO input for safety.
- Use both EtherNet/IP ports for the network.
- Fit an external shunt if braking energy is high.
- Keep one power cycle per minute max.
- Use the 2198-K53CK-D15M kit for flying-lead feedback cables.
- Set ramps with RampAcceleration and RampDeceleration in Studio 5000.
Compatibility and Extras
- Works with Logix 5000 controllers and Studio 5000 Logix Designer.
- No RS-485 or Modbus port.
- Optional 2198-CONKIT-PWR20 connector set.
- Optional 2198-TCON-24VDCIN36 for shared 24V bus power.
- Supports CIP Security with FactoryTalk and Studio 5000 v32+.
- Accepts Hiperface, Nikon, Tamagawa, and incremental feedback.
Certifications
- cULus: UL 61800-5-1, File E59272
- CE: EMC IEC 61800-3, LVD IEC 61800-5-1
- Functional safety: TÜV, PL d / Cat 3 / SIL CL2
- RCM: Australian Radiocommunications Act, AS/NZS CISPR 11 Class A
- KC: KCC-REM-RAA-2198
- ODVA: EtherNet/IP and CIP Security conformance
- Ecodesign: IE2 class, EU 2019/1781
- Noise: under 85 dBA, OSHA 3074
- Note: UL has not evaluated the STO option.
FAQ
- Q: Can this drive run a motor with a brake?
A: Yes. It has a built-in brake relay. Keep the brake at or under 2.25 A and below 15 cycles per minute. - Q: What feedback types does it accept?
A: It reads Hiperface, Nikon, Tamagawa, and incremental encoders. Pair it with the 2198-K53CK-D15M kit for flying-lead cables. - Q: The motor hums at standstill. What should I check first?
A: Check the feedback cable shield and grounding. Loose shields often cause noise. Also verify the commutation offset in Studio 5000. - Q: How much braking energy can the internal shunt take?
A: The internal shunt handles 30 W. For high-inertia loads, add a 2097-R6 or 2097-R7 external unit. - Q: Why does the drive fault on power-up?
A: The bus undervoltage trip is 275V. Check the 24V control supply first. Then check the three-phase input for a loose phase.




There are no reviews yet.